
 EMOS
Simulation Quick Starts#
Ready to see EMOS in action? This page walks you through launching a full autonomous navigation stack in simulation using either Webots or Gazebo. Each section is self-contained – pick the simulator you prefer and follow along.
Webots Simulator#
Launch a full autonomous navigation stack in under 5 minutes.
In this tutorial, we use a single Python script – a “Recipe” – to build a complete point-to-point navigation system. We will use the Webots simulator and a Turtlebot3 to demonstrate how EMOS components link together.
1. Prepare the Environment#
To make things easy, we created kompass_sim, a package with ready-to-launch simulation environments.
Build the Simulation: Clone and build the simulator support package in your ROS2 workspace:
git clone https://github.com/automatika-robotics/kompass-sim.git
cd .. && rosdep install --from-paths src --ignore-src -r -y
colcon build --packages-select kompass_sim
source install/setup.bash
Launch Webots: Start the Turtlebot3 simulation world. This will bring up Webots, RViz, and the robot localization nodes:
ros2 launch kompass_sim webots_turtlebot3.launch.py
Tip
No ROS install for the simulator? The same simulation ships as a container, with Webots, the robot driver, localization and RViz inside. It shares the host’s network, so the recipe running on the host finds it as if it were local:
docker pull automatika/kompass-sim:jazzy
xhost +local:root
docker run -it --rm --network host --ipc host \
  --env DISPLAY="$DISPLAY" --env QT_X11_NO_MITSHM=1 \
  --volume /tmp/.X11-unix:/tmp/.X11-unix:rw --device /dev/dri:/dev/dri \
  automatika/kompass-sim:jazzy
On an NVIDIA GPU add --gpus all --env NVIDIA_DRIVER_CAPABILITIES=all and drop the --device flag. Both sides have to share the same ROS_DOMAIN_ID and RMW implementation.
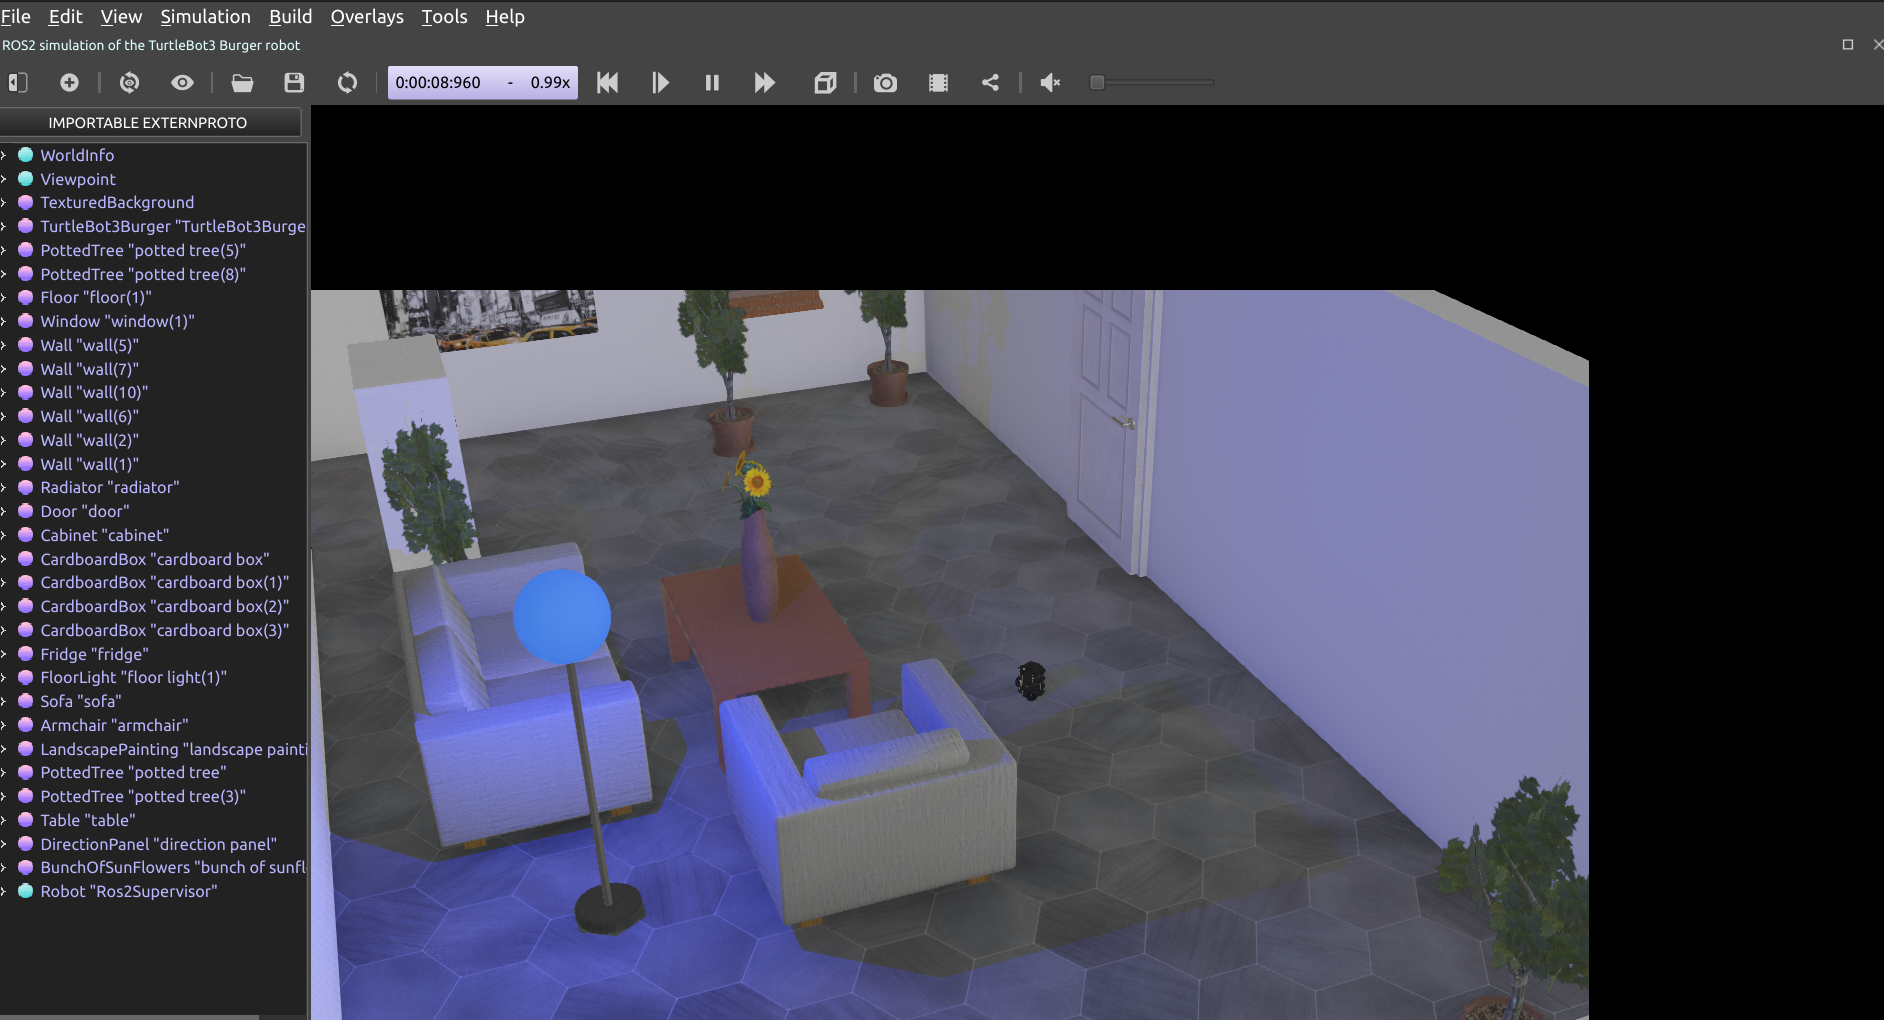
The Webots world: a Turtlebot3 Burger in a furnished apartment.#
3. Run and Navigate#
Open a new terminal and run your recipe:
python3 quick_start.py
You will see the components starting up in the terminal. Once ready, you have two ways to control the robot.
Option A: The EMOS Web UI#
The recipe includes launcher.enable_ui(...), which automatically spins up a lightweight web interface for monitoring and control.
Check Terminal: Look for the log line
Access the recipe UI at: https://<IP_ADDRESS_OF_THE_ROBOT>:5001and open that address, accepting the self-signed certificate once.Open Browser: Navigate to that URL.
Send Goal: You will see the map, the plan and the robot’s live position. Send a goal from the
/clicked_pointinput and the robot heads there.
Option B: RViz#
If you prefer the standard ROS tools:
Go to the RViz window launched in Step 1.
Select the Publish Point tool (sometimes called
Clicked Point) from the top toolbar.Click anywhere on the map grid.
The robot will plan a path (Blue Line) and immediately start driving.
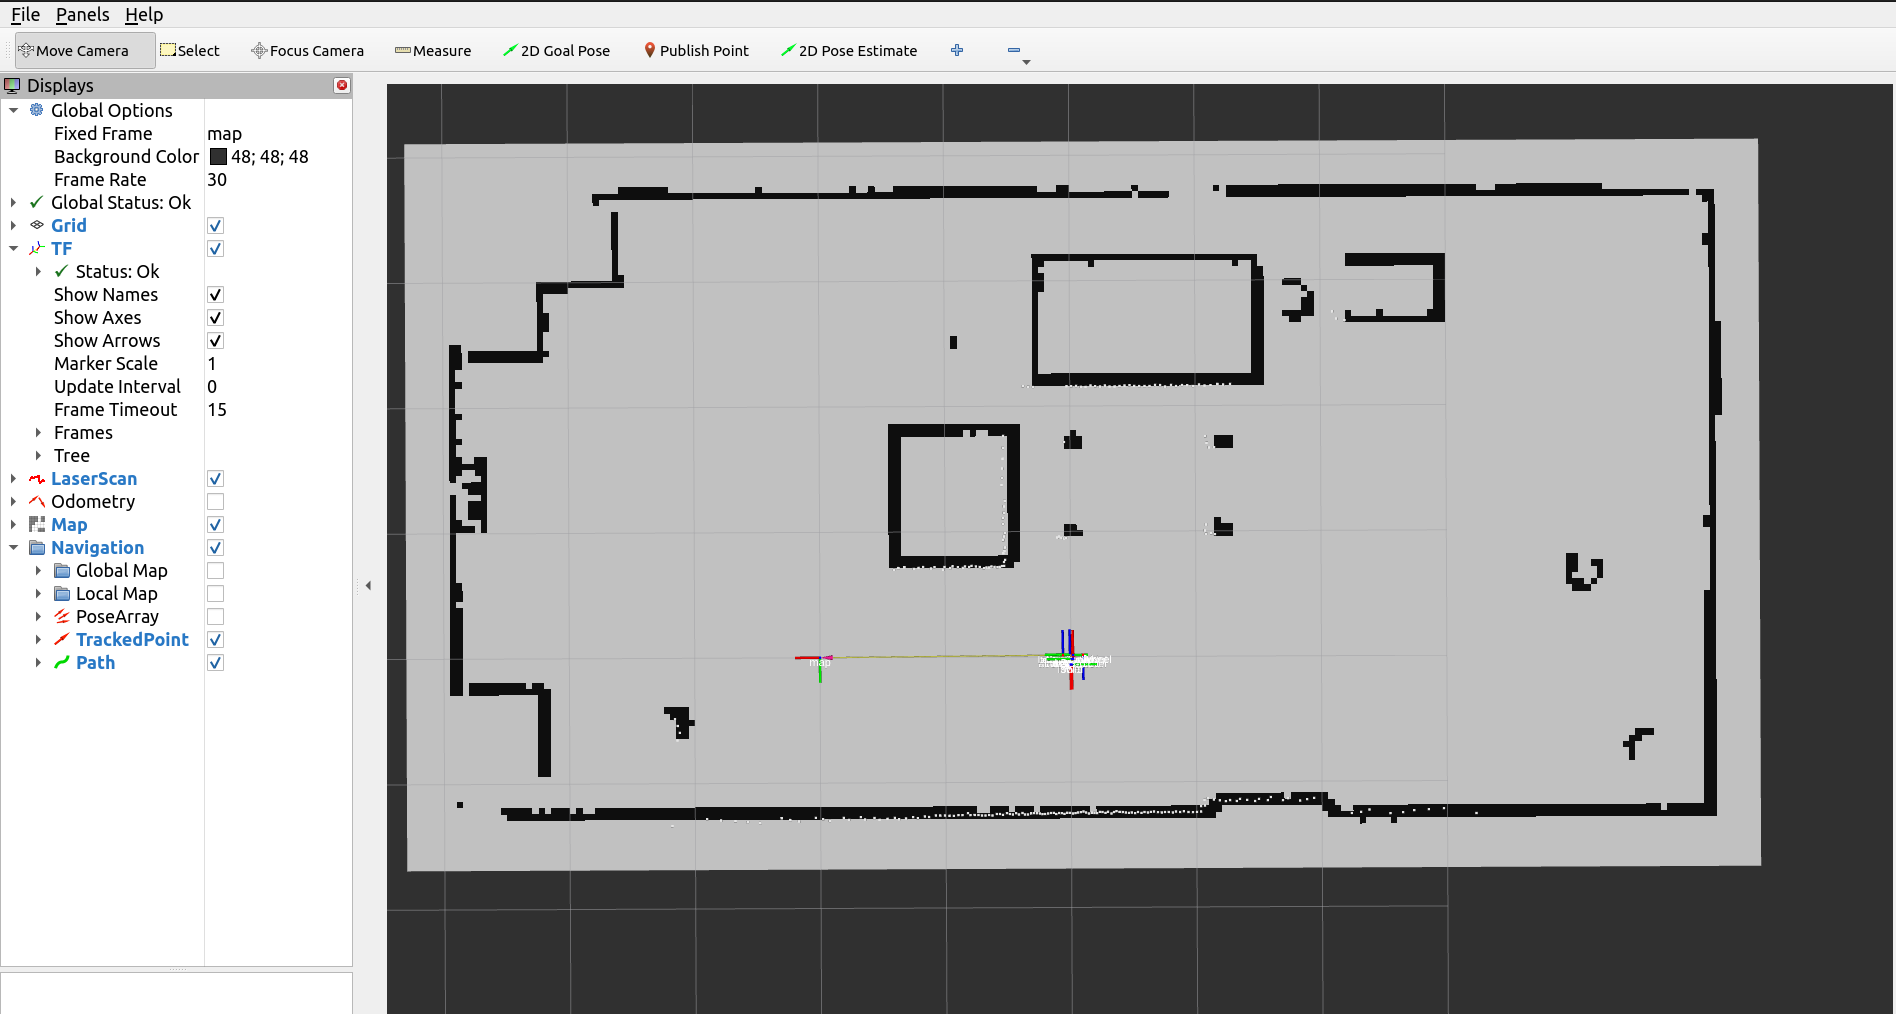
RViz with the map of the Webots world, the robot’s frames and the Publish Point tool in the toolbar.#
What just happened?#
Components: You configured your robot and the navigation components directly in your Python recipe.
Launcher: Automatically managed the lifecycle of 5 ROS2 nodes in multi-processing.
Web UI: Visualized the map, plan, and odometry topics instantly without installing extra frontend tools.
Gazebo Simulator#
Launch a full autonomous navigation stack in under 5 minutes.
In this tutorial, we use a single Python script – a “Recipe” – to build a complete point-to-point navigation system. We will use the Gazebo simulator and a Turtlebot3 Waffle Pi to demonstrate how EMOS components link together.
1. Install Gazebo#
If you haven’t already, install the default Gazebo version for your ROS distribution (replace ${ROS_DISTRO} with humble, jazzy, or rolling):
sudo apt-get install ros-${ROS_DISTRO}-ros-gz
2. Prepare the Environment#
To make things easy, we created kompass_sim, a package with ready-to-launch simulation environments.
Build the Simulation: Clone and build the simulator support package in your ROS2 workspace:
git clone https://github.com/automatika-robotics/kompass-sim.git
cd .. && rosdep install --from-paths src --ignore-src -r -y
colcon build --packages-select kompass_sim
source install/setup.bash
Set the Model: Tell the simulation to use the “Waffle Pi” model:
export TURTLEBOT3_MODEL=waffle_pi
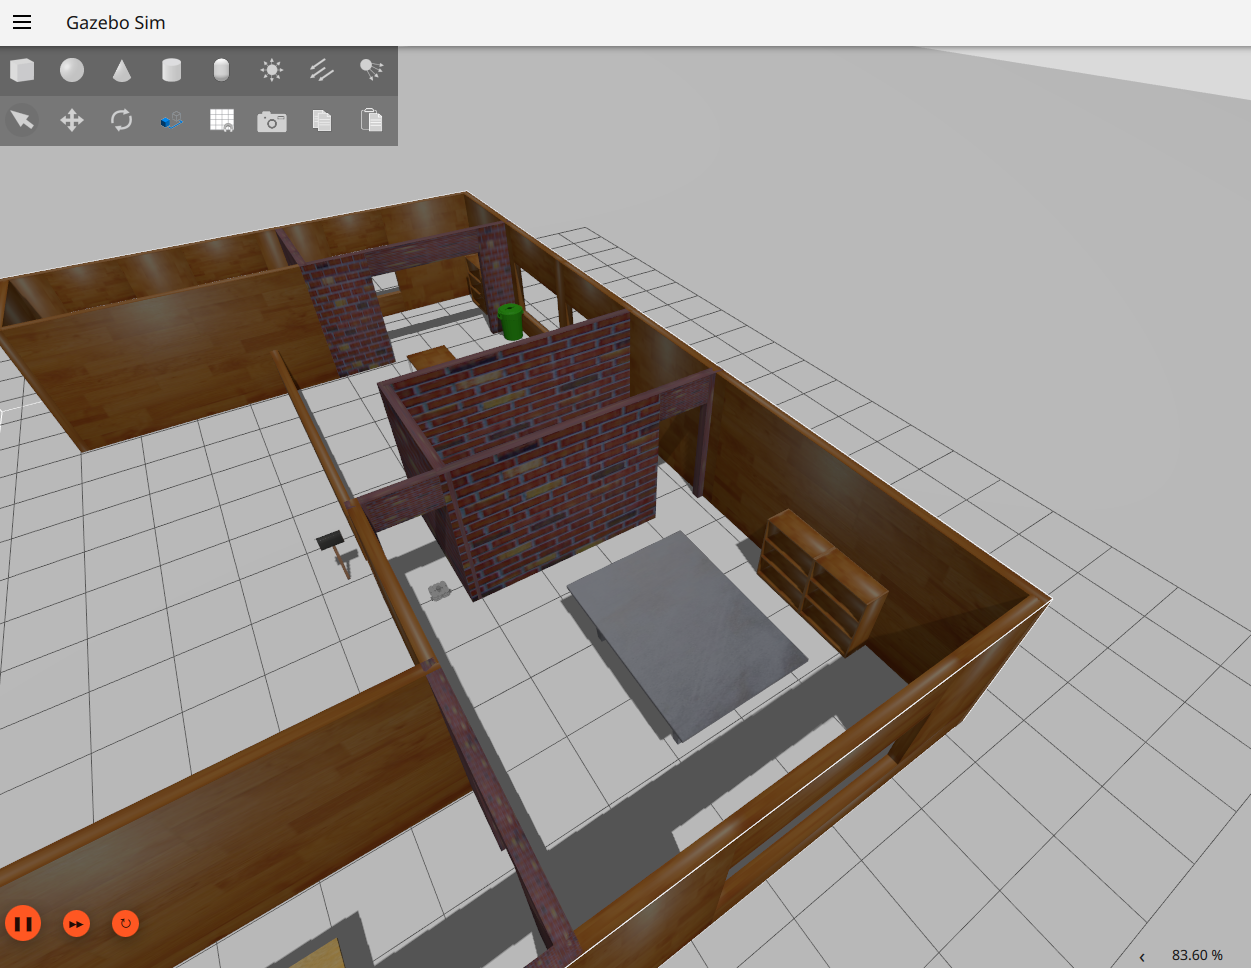
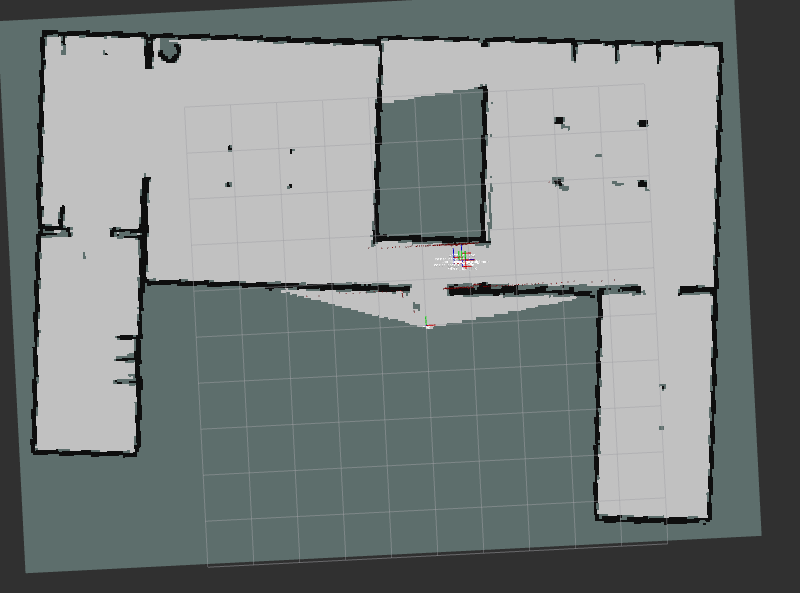
Launch Gazebo: Start the Turtlebot3 house simulation. This will bring up Gazebo, RViz, and the localization nodes:
ros2 launch kompass_sim gazebo_turtlebot3_house.launch.py
3. The Navigation Recipe#
The power of EMOS lies in its Python API. Instead of complex XML/YAML launch files, you define your navigation logic in a clean script.
Create a file named quick_start_gz.py and paste the following code:
import numpy as np
import os
from ament_index_python.packages import get_package_share_directory

# IMPORT ROBOT CONFIG PRIMITIVES
from kompass.robot import (
    AngularCtrlLimits,
    LinearCtrlLimits,
    RobotGeometryType,
    RobotType,
    RobotConfig,
)

# IMPORT EMOS NAVIGATION COMPONENTS
from kompass.components import (
    Controller,
    DriveManager,
    DriveManagerConfig,
    Planner,
    PlannerConfig,
    LocalMapper,
    LocalMapperConfig,
    MapServer,
    MapServerConfig,
    TopicsKeys,
)

# IMPORT ALGORITHMS CONFIG
from kompass.control import ControllersID, MapConfig

# IMPORT ROS PRIMITIVES
from kompass.ros import Topic, Launcher, Event, Action, actions


kompass_sim_dir = get_package_share_directory(package_name="kompass_sim")

# Setup your robot configuration (Turtlebot3 Waffle Pi)
my_robot = RobotConfig(
    model_type=RobotType.DIFFERENTIAL_DRIVE,
    geometry_type=RobotGeometryType.BOX, # Waffle Pi is rectangular
    geometry_params=np.array([0.3, 0.3, 0.2]), # Length, Width, Height
    ctrl_vx_limits=LinearCtrlLimits(max_vel=0.26, max_acc=1.0, max_decel=1.0),
    ctrl_omega_limits=AngularCtrlLimits(
        max_omega=1.8, max_acc=2.0, max_decel=2.0, max_ang=np.pi / 3
    ),
)

# Configure the Global Planner
planner_config = PlannerConfig(loop_rate=1.0)
planner = Planner(component_name="planner", config=planner_config)
planner.run_type = "Timed"
# Goals arrive on /clicked_point, from RViz's Publish Point tool or the web UI
goal = Topic(name="/clicked_point", msg_type="PointStamped")
planner.inputs(goal_point=goal)

# Configure the motion controller
controller = Controller(component_name="controller")
controller.algorithm = ControllersID.PURE_PURSUIT
controller.direct_sensor = (
    False  # Get local perception from a "map" instead (from the local mapper)
)

# Configure the Drive Manager (Direct commands sending to robot)
driver_config = DriveManagerConfig(
    critical_zone_distance=0.05,
    critical_zone_angle=90.0,
    slowdown_zone_distance=0.3,
)
driver = DriveManager(component_name="drive_manager", config=driver_config)

# Handle Twist/TwistStamped compatibility
if "ROS_DISTRO" in os.environ and (
    os.environ["ROS_DISTRO"] in ["rolling", "jazzy", "kilted"]
):
    cmd_msg_type: str = "TwistStamped"
else:
    cmd_msg_type = "Twist"

driver.outputs(robot_command=Topic(name="/cmd_vel", msg_type=cmd_msg_type))

# Configure a Local Mapper
local_mapper_config = LocalMapperConfig(
    map_params=MapConfig(width=3.0, height=3.0, resolution=0.05)
)
local_mapper = LocalMapper(component_name="mapper", config=local_mapper_config)

# Configure the global Map Server
# Note: We use the 'house' map to match the Gazebo world
map_file = os.path.join(kompass_sim_dir, "maps", "turtlebot3_gazebo_house.yaml")
map_server_config = MapServerConfig(
    loop_rate=1.0,
    map_file_path=map_file,
    grid_resolution=0.5,
    pc_publish_row=False,
)
map_server = MapServer(component_name="global_map_server", config=map_server_config)

# Setup the launcher
launcher = Launcher()

# Add navigation components
launcher.add_pkg(
    components=[map_server, controller, planner, driver, local_mapper],
    package_name="kompass",
    multiprocessing=True,
)

# Get odom from localizer filtered odom for all components
odom_topic = Topic(name="/odometry/filtered", msg_type="Odometry")
launcher.inputs(location=odom_topic)

# Set the robot config and frames
launcher.robot = my_robot

# Enable the UI
# Outputs: Static Map, Global Plan, Robot Odometry
launcher.enable_ui(
    inputs=[goal],
    outputs=[
        map_server.get_out_topic(TopicsKeys.GLOBAL_MAP),
        odom_topic,
        planner.get_out_topic(TopicsKeys.GLOBAL_PLAN),
    ],
)

# Run the Recipe
launcher.bringup()
4. Run and Navigate#
Open a new terminal and run your recipe:
python3 quick_start_gz.py
You will see the components starting up in the terminal. Once ready, you have two ways to control the robot.
Option A: The EMOS Web UI#
The recipe includes launcher.enable_ui(...), which automatically spins up a lightweight web interface for monitoring and control.
Check Terminal: Look for the log line
Access the recipe UI at: https://<IP_ADDRESS_OF_THE_ROBOT>:5001and open that address, accepting the self-signed certificate once.Open Browser: Navigate to that URL.
Send Goal: You will see the map, the plan and the robot’s live position. Send a goal from the
/clicked_pointinput and the robot heads there.
Option B: RViz#
If you prefer the standard ROS tools:
Go to the RViz window launched in Step 2.
Select the Publish Point tool (sometimes called
Clicked Point) from the top toolbar.Click anywhere on the map grid.
The robot will plan a path (Blue Line) and immediately start driving.
What just happened?#
Customization: We adapted the robot configuration (
RobotConfig) to match the Waffle Pi’s rectangular geometry. Sensor frames need no configuration: every component reads them from the messages and TF.Launcher: Managed the lifecycle of the entire stack.
Perception: The Local Mapper is processing the Gazebo laser scan to provide obstacle avoidance data to the Controller.
Next Steps#
Tip
Check the Point Navigation recipe for a deep dive into these recipes.
Tip
Promote this recipe to production. While you are shaping it, run the script directly with python recipe.py. Once it is solid, drop it at ~/emos/recipes/<name>/recipe.py and start it with emos run <name>, or from the dashboard. Either way every run is logged under ~/emos/logs, and an operator gets a card to launch it from a browser. Running Recipes covers the two ways of running a recipe and what differs per install mode.